


PLAUSU Project
The project entitled “AUTONOMOUS PLATFORM FOR URBAN SERVICES” (PLAUSU), with reference number IDI-20230275, has been funded by the CENTRE FOR INDUSTRIAL TECHNOLOGICAL DEVELOPMENT (CDTI) and co-funded by the EUROPEAN REGIONAL DEVELOPMENT FUND (ERDF) through the Multi-regional Operational Programme for Spain (2014–2020), with an approved project budget of €1,157,991 and a grant of €984,292.35.
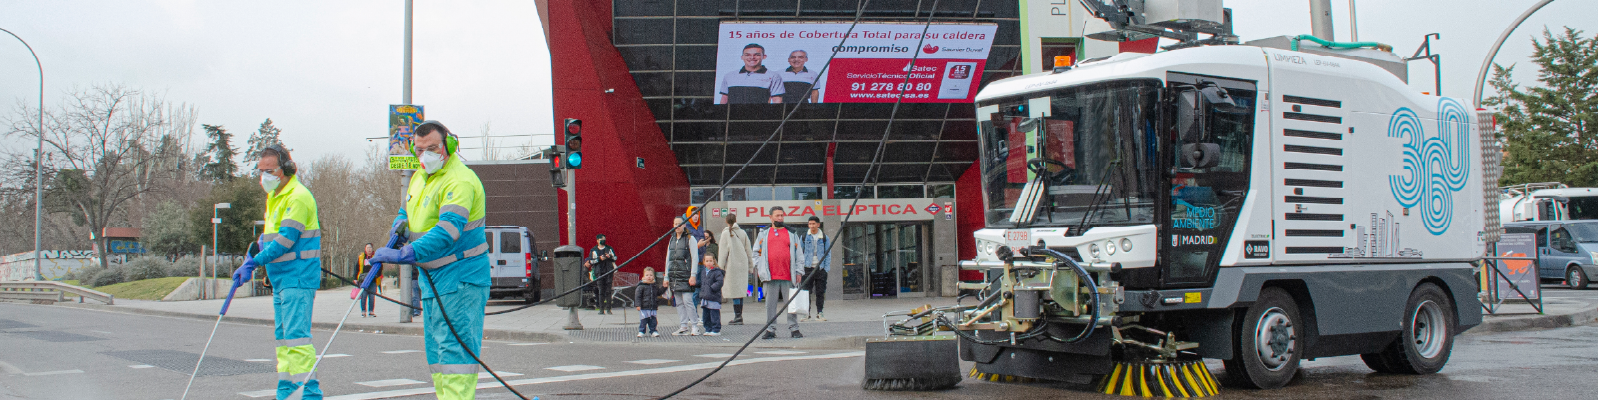
The objective of the project is to research and develop automation technologies, specifically focused on urban service vehicles, and to implement these developments on a dual-purpose sweeper-scrubber that already incorporates a fully electric propulsion and service drive system, enabling it to operate autonomously whilst carrying out cleaning tasks.
The project successfully developed the automation of an autonomous sweeper, managing to generate automation technologies applicable to urban service vehicles. Advanced digital navigation algorithms (LIO-SAM) were developed, as well as perception algorithms for detecting operators and pedestrians (with an accuracy of over 98 per cent); the ‘Follow Me’ intelligent tracking system was implemented, along with remote automation of the machine. Real-world trials validated the functional prototype, demonstrating the technical feasibility of automation in urban services.
The project ran from 1 November 2022 to 30 April 2026 and was carried out in Madrid and Barcelona, utilising the facilities of FCC Medio Ambiente and the INSTITUTO UNIVERSITARIO DE INVESTIGACIÓN DE AUTOMÓVIL (INSIA).
